About

I am a master's student in Mechanical Engineering at Beijing Institute of Technology, supervised by Prof. Jieliang Zhao in BIB Lab.

My research focuses on bioinspired adhesion, soft robotics and dexterous manipulation.

My projects span humanoid robot hardware, dexterous mechanisms and Formula Student chassis, from CAD and simulation to prototyping and assembly. I use SolidWorks, Abaqus, ADAMS and MuJoCo, alongside Codex for engineering tool development.

I am currently seeking mechanical engineering roles in robotics, consumer electronics, medical devices and related fields. I would be grateful for the opportunity to connect and discuss how I could contribute to your team.

Email: xyu8468@gmail.com

Education & Teams

  1. – Present

    Beijing Institute of Technology

    Undergraduate
    –
    Master’s student
    – PresentMechanical Engineering
  2. –

    BITFSAE

    Chassis Lead → Mechanical Systems Lead → Team Captain

  3. BIB Lab

    Joined the Laboratory of Biological Intelligence and Biomimetics

  4. –

    ByteDance Seed Robotics

    Robotics Hardware Intern (Mechanical Engineering)

Publications

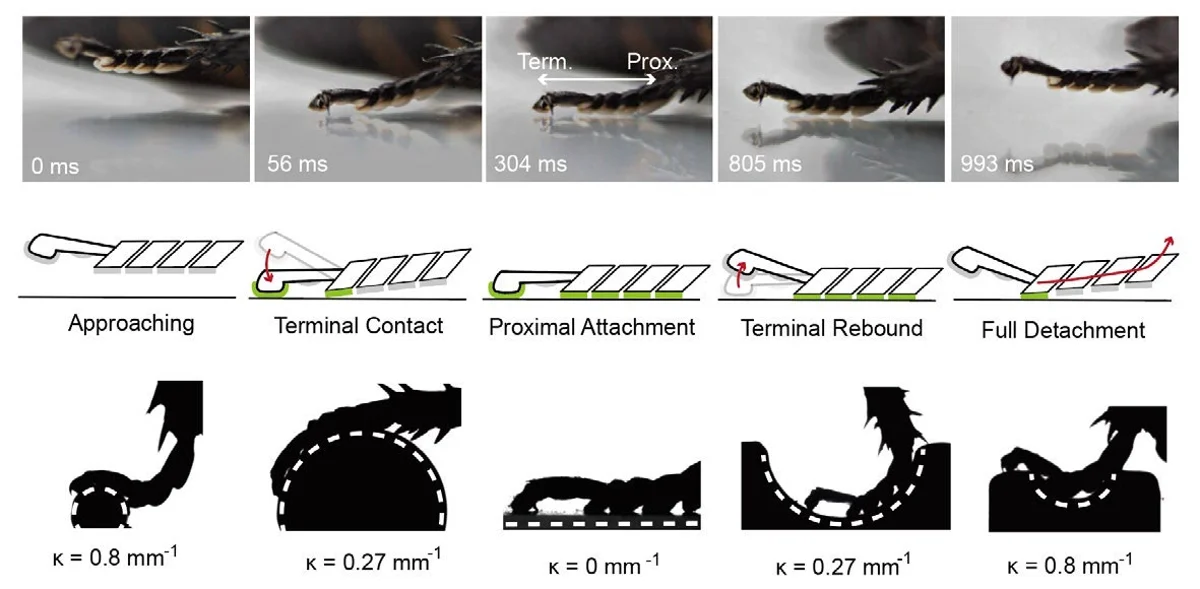
Insect tarsal attachment and detachment sequence

Insect Tarsus-Inspired Variable-Stiffness Adhesion for Extreme Space Manipulation

Yu Xiang, et al.

Manuscript in preparation

Projects

Engineering project

Formula Student Racing Car

2020–2024 · Chassis lead (years 1–2) · Mechanical systems lead (year 3) · Team captain (year 4)

Design and validate suspension, steering and vehicle structures, connecting simulation with manufacturing, alignment and track testing.

Research project · In progress

Insect-Inspired Dexterous Grasping (Ongoing)

In progress · Independent research

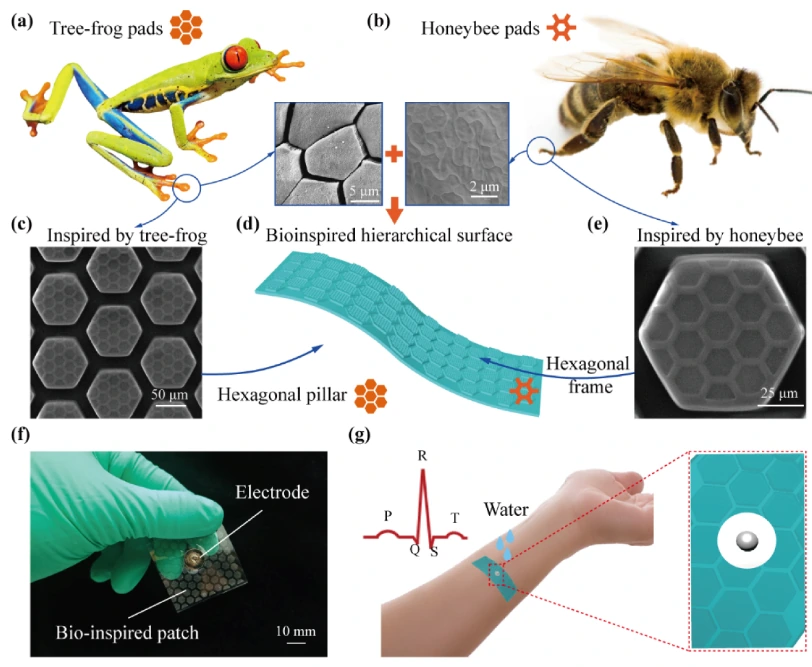
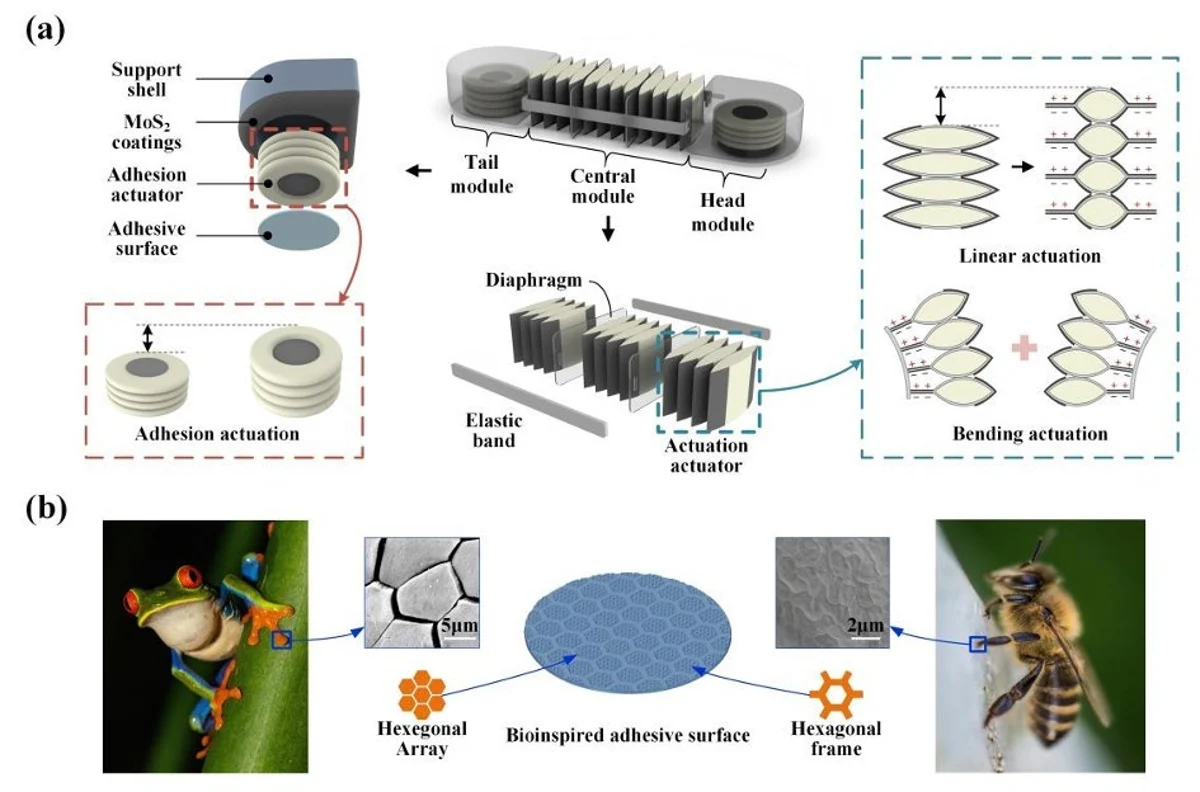
Investigate insect-inspired wet adhesion and segmented, tendon-driven fingertips for conformal contact, load transfer and controlled release.

Collaborative engineering project

Origami-Based Insect-Inspired Wall-Climbing Robot

November 2020–September 2021 · Team leader

Design and assemble an insect-inspired climbing robot combining an origami body, four-bar linkage legs, adaptive ankles and negative-pressure suction cups.

Media & Activities